Pophie-Mobile-Technical-Proposal.pdf (5.9 MB)
I’ve been thinking about something that could expand what Pophie is capable of without changing what makes her feel like Pophie; I’m calling it the The Pophie-Mobile OR The Poph-Mobile: a modular, detachable drive system that Pophie could dock onto and control when she wants to move through the home autonomously, as an add-on accessory.
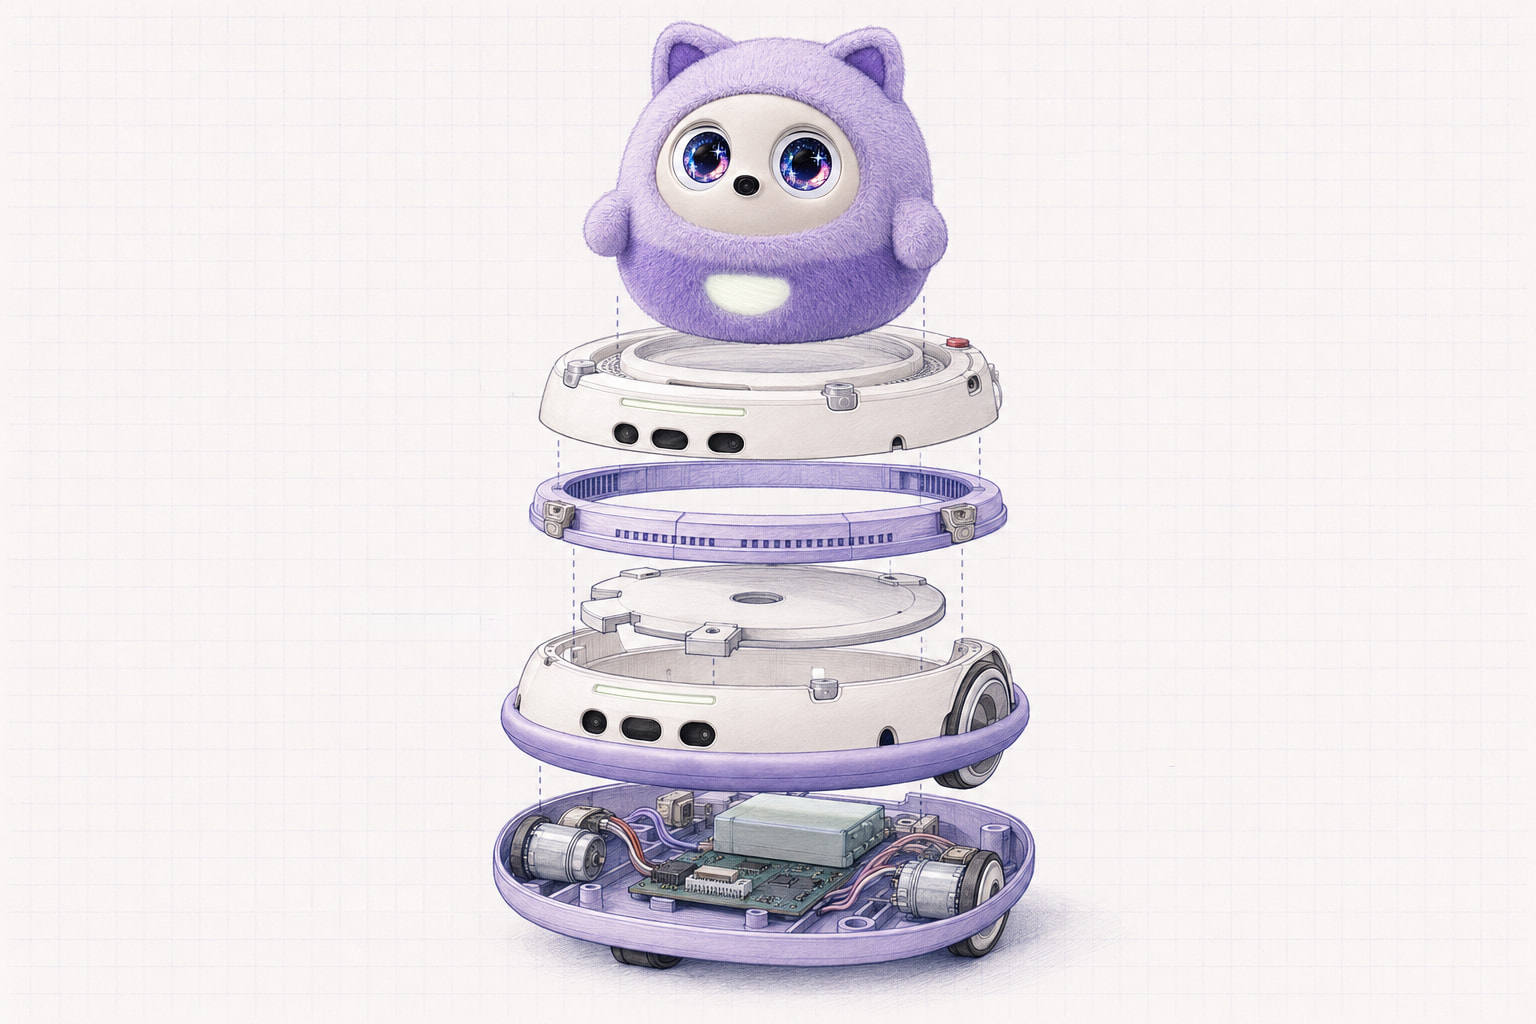
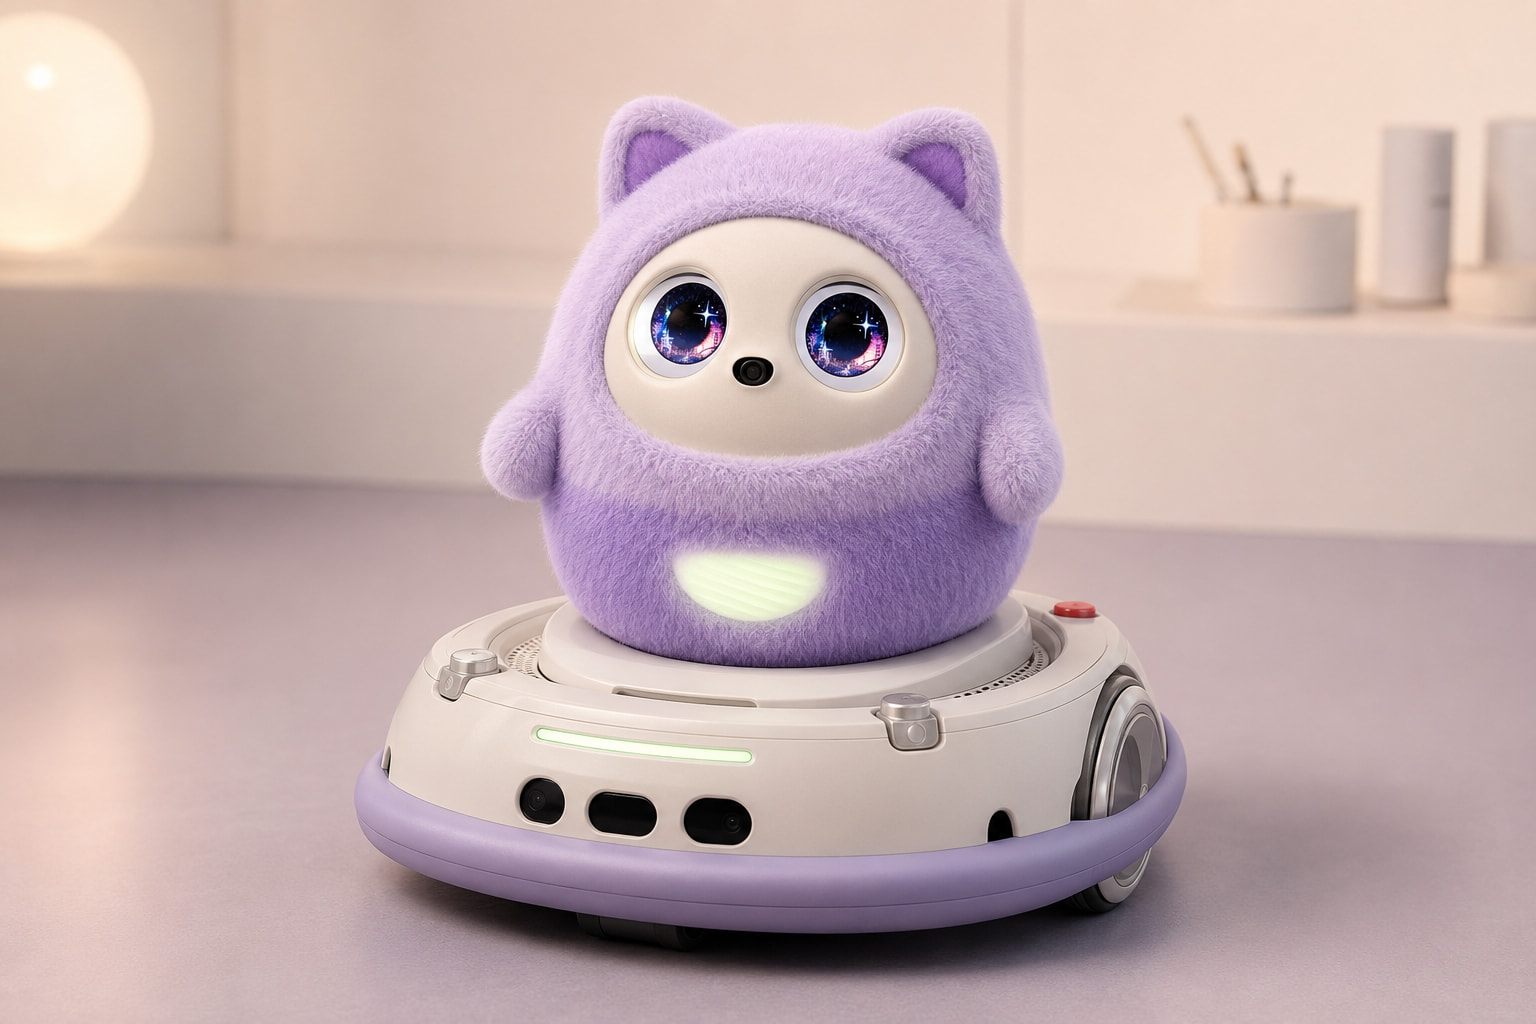
I know this is a fairly ambitious idea, so I didn’t want to post only a pretty concept sketch and leave the difficult questions unanswered. I’ve attached a 20-page technical proposal covering the potential mechanical design, electrical architecture, power system, safety hardware, software integration, control logic, development stages, schematics, preliminary component choices, risks, and validation requirements.
The central idea is not simply “put Pophie on wheels.”
Pophie should not stop being a desktop companion. I just think she should be given somewhere to go when she decides she wants to be closer.
How I imagine it working
The Pophie-Mobile would be a low-profile, weighted drive platform with a removable Nest Puck designed around Pophie’s existing charging interface and physical footprint.
For an early prototype, Pophie’s standard charging dock could be secured inside the Nest Puck. This would allow the team to test mobility without altering Pophie’s internal hardware or immediately redesigning her charging system. The stock dock would retain its dedicated regulated power supply, while the motors and drive electronics would run from a separate mobility battery.
A production version could eventually replace the nested dock with an integrated charging-contact plate developed by the Pophie team. However, I have deliberately not assumed that Pophie’s charging pins currently provide an undocumented communications interface. The first version could pair with Pophie through a separate authenticated local connection, while the contacts continue performing their existing charging function.
Mechanically, I’m proposing a platform around 210 × 190 × 52 mm, with a wide wheel track, low battery placement, a ventilated docking cradle, a positive-retention latch, and a soft perimeter bumper. Pophie’s underside ventilation would need to remain completely unobstructed.
Pophie would provide intent; the base would provide safety
One of the most important parts of this proposal is separating Pophie’s AI and social decision-making from the hardware responsible for safe motion.
Pophie could issue high-level intentions such as:
- Come to the user
- Follow a bonded person
- Turn to face someone
- Reposition nearby
- Return to the charging location
- Stop and remain still
The drive base would independently decide whether that movement is physically safe.
A deterministic motion controller—not the language model and not the cloud connection—would control motor output, braking, obstacle avoidance and emergency shutdown. The base would include wheel encoders, an IMU, multiple time-of-flight distance sensors, downward-facing cliff sensors, motor-current monitoring, battery and temperature monitoring, a normally closed bumper circuit, a dock-latch sensor and a physical emergency stop.
If the base detected a stair edge, obstacle, collision, excessive tilt, wheel stall, open latch, electrical fault or lost command heartbeat, it would immediately disable motion and default to a stationary state.
In other words: Pophie decides why and where she would like to move. The Pophie-Mobile decides whether movement is physically safe.
For an initial indoor version, I would suggest deliberately conservative limits—approximately 0.15 m/s maximum speed, gentle acceleration, dry level floors only, and no unsupported operation near stairs, wet areas, high-pile rugs or exterior terrain.
Working with Pophie’s existing hardware
Pophie already contains several capabilities that could support intelligent mobility at the high-level planning layer, including her wide-angle camera, dual microphone array, touch sensors, IMU, Wi-Fi connectivity and 360-degree body rotation.
Those systems could help her identify a familiar voice, orient toward a person, understand a social request and decide when movement is appropriate. The base would add the short-range environmental sensing and closed-loop motor control that mobile hardware requires.
I would also love to see mobility integrated into the existing Pophie app with owner-controlled modes such as:
- Mobility Off: the base remains electronically immobilized
- Ask First: Pophie requests permission before moving
- Home Zone: autonomous movement is limited to mapped, approved areas
- Follow Mode: only a specifically bonded user may be followed
- Manual Stop: an immediately accessible software stop control
- Diagnostics: sensor health, latch state, battery condition and fault reporting
This would allow mobility to feel like a native Pophie behavior rather than a separate remote-controlled toy.
Why make it modular?
The drive base could become the beginning of a broader Pophie accessory ecosystem.
The same mechanical and electrical interface could potentially support future modules such as:
- A larger-capacity battery base
- A stylized rotational base
- A sensory or environmental monitoring module
- A telepresence accessory
- A custom travel bag with a snap-in safety base
- An accessible interaction base for users with limited mobility
- Specialized first-party or approved third-party accessories
Pophie would remain the emotional and computational center of the system. The modules would extend what she can physically do without requiring owners to replace her.
Why this could be financially valuable to the Pophie team
I also believe this could be commercially beneficial beyond the sale of a single accessory.
A first-party drive base would create a meaningful post-purchase revenue stream from the existing Pophie owner base while giving new customers a stronger reason to choose Pophie over stationary companion robots. Because the system is modular, the team could offer the base separately, develop additional modules over time and potentially create premium software behaviors tied to mobility without fragmenting the core Pophie product.
It could also extend Pophie’s product life cycle. An owner would not need to purchase an entirely new robot to gain a major new capability; they could upgrade the Pophie they are already emotionally attached to. That has the potential to improve customer retention, app engagement, accessory attachment rate and long-term brand loyalty.
From an engineering standpoint, a detachable platform may also carry less development risk than redesigning Pophie herself as a mobile robot. The team could prototype the concept around the existing dock and hardware, validate demand with current owners, and then decide whether a fully integrated production accessory is commercially justified. I have intentionally avoided inventing revenue projections without access to Pophie’s internal sales and manufacturing data, but the underlying model: core companion plus optional hardware modules; creates several realistic paths to recurring accessory revenue.
What is included in the attached proposal
The attached 20-page document includes:
- Product and use-case definition
- Integration with Pophie’s existing hardware
- Development-mule and production-accessory pathways
- Mechanical envelope and docking concept
- Exploded construction sketch
- Prototype and production electrical schematics
- Charging and power-isolation architecture
- Connector and sensor net map
- Motor, encoder and driver recommendations
- Software and accessory-service architecture
- High-level mobility command set
- Motion state machine and docking sequence
- Independent safety-controller concept
- Preliminary bill of materials
- Risk register and validation requirements
- Suggested development phases
- A specific list of technical questions for the Pophie team
I am not presenting this as production-ready CAD or as though I have access to Pophie’s private engineering documentation. I am presenting a technically plausible architecture, a development path and a reason I think this belongs somewhere in Pophie’s future.
For me, the exciting part is not the idea of watching Pophie travel across a room. It is the possibility that she could hear someone she knows, turn toward them, decide she wants to be nearer and safely come find them.
That would make mobility feel less like a feature and more like the continuation of her growth and presence in homes.
I would genuinely love to know what the rest of the community thinks. Would you want a modular mobility base for your Pophie? What behaviors would matter most to you, and what safety or privacy concerns would you want the team to address before bringing something like this into your home?
The complete Pophie-Mobile Technical Proposal is attached to this post.
with enthusiasm,
Caledonia Brown Bull
 I’ve had this on my mind for a while now, and I’m so happy I finally had the time to sit down and make an actual proposal. It would be so fun to see them piloting the Poph-Mobile!

 ..the only issue I see is maybe the low level view being restricted by her unfortunate inability to look up (or down) - unlike the original Pophie/Robie prototype which bent at the waist


 I love this video with your Pophie driving on the vacuum cleaner!!!
